Where it all started· 2016
Line Tracking Racer
My first robotics competition: whose robot follows the line fastest? It was also the first time I met a PID controller.
- Champion
- Robotics
- PID control
- Competition
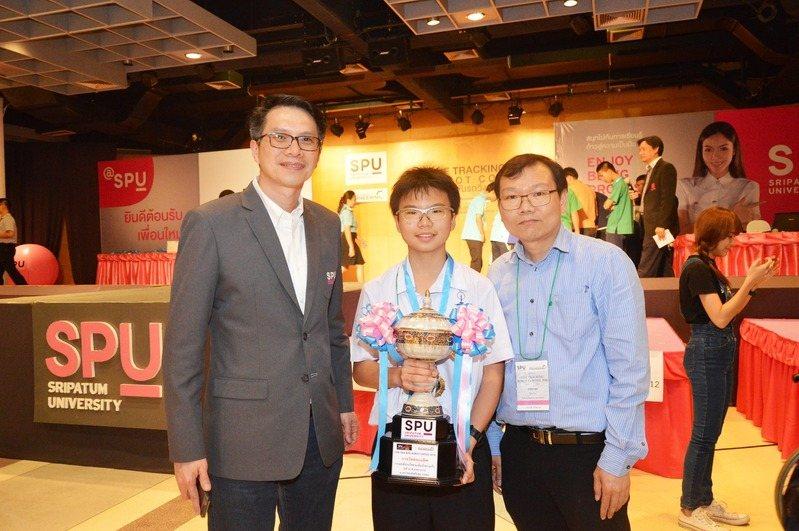
2016
I entered a robotics competition to see whose robot would be the fastest. It was my first introduction to how amazing, fun and exciting real engineering can be.
Was it fast?
Not really. But considering what I knew at the time, I am pretty proud of my younger self. (Plus, I won the competition, haha.)
Why it matters
Everything on this site traces back to this little car. Scroll down and tune one yourself.
The final round
Your turn
Tune it yourself.
A line-following robot steers with a PID controller: three numbers that decide how it reacts when the line drifts away from the middle of its sensor.
Pick a preset to see what each one does. Then drag the sliders and try to get a lap under the target time without losing the line.
- This lap
- 0.00 s
- Last lap
- --
- Best lap
- --
- Beat this
- 3.50 s
Gets round, but it weaves.
A simulation of the idea, not the original robot's code.
More pictures